grabowski
ba1f5fc3a9
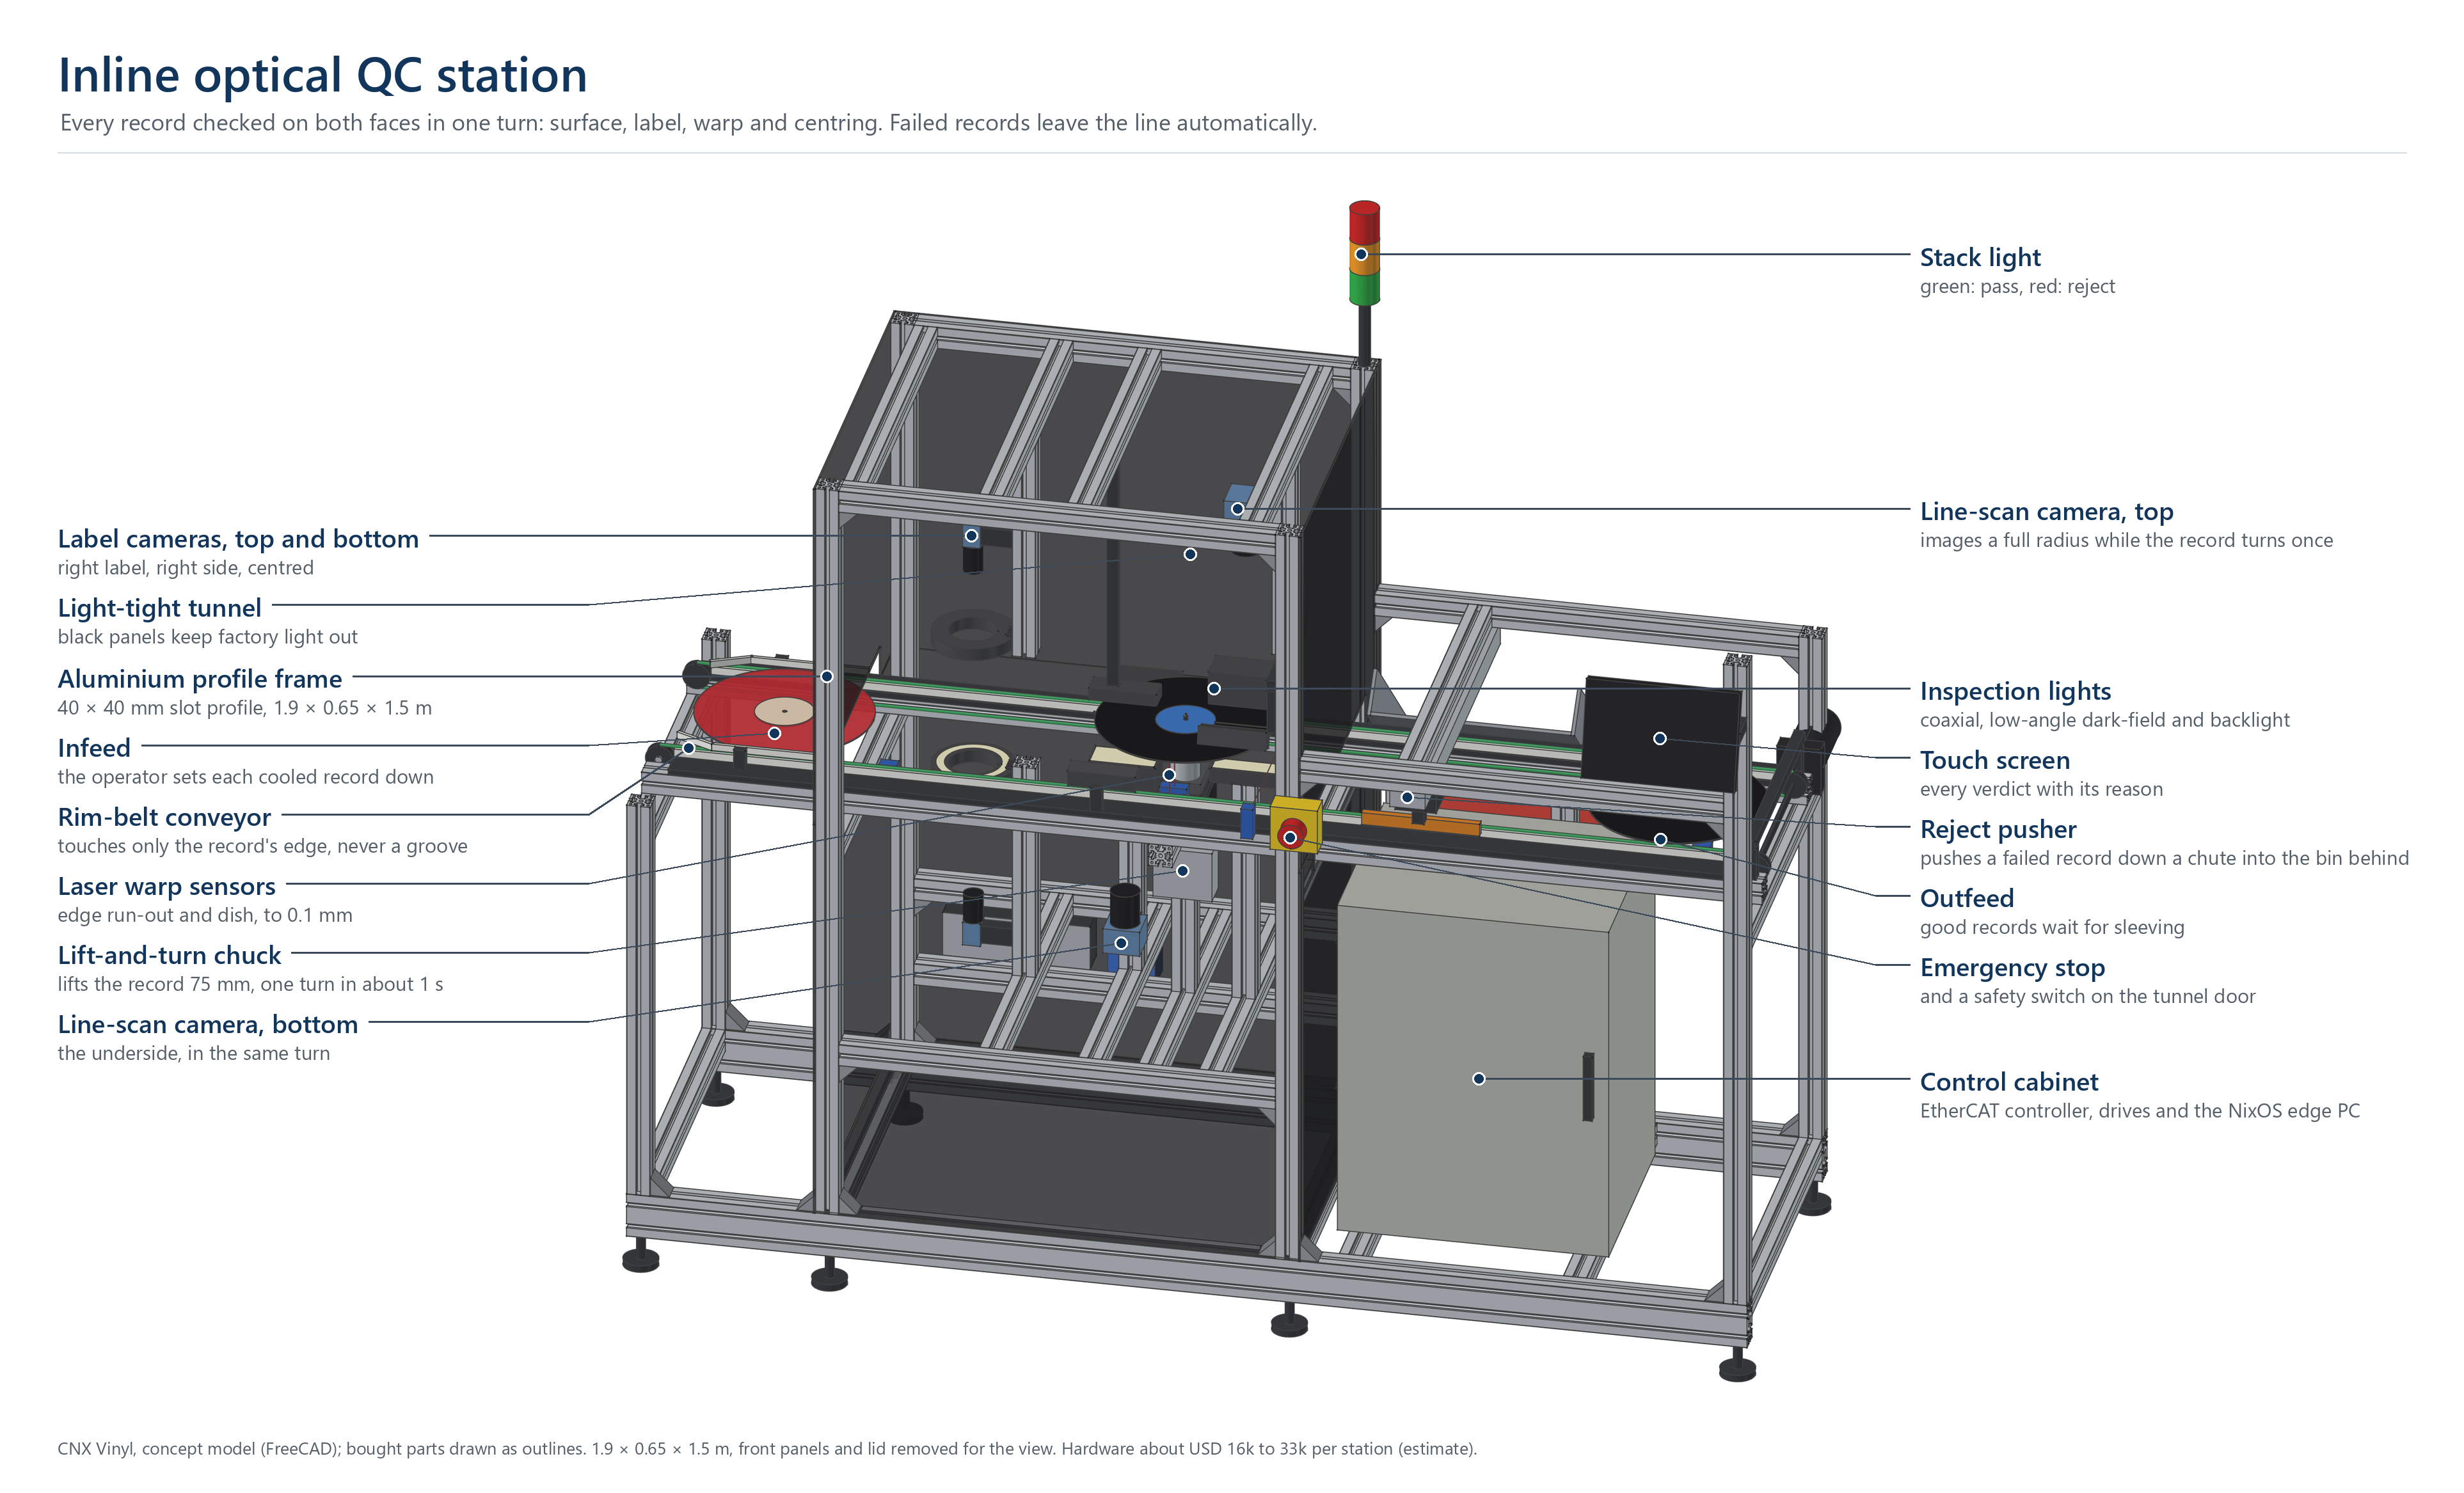
User, 18 Oct 2026: use an EtherCAT based system.

- Spindle and conveyor on the StepperOnline A6-EC100L2A1-M17 kit
  (100 W, A6-200EC drive, USD 123.29), spindle through a 1:6 belt in
  cyclic synchronous position, conveyor in cyclic synchronous velocity.
- The A6-EC drive has no divided encoder output, so an RS-422
  incremental encoder on the spindle shaft clocks both line-scans; its
  index goes to the drive touch probe for one angle reference.
- Station controller: fanless N100 mini PC with 2x Intel i226, NixOS
  PREEMPT_RT, EtherCAT master EtherCrab (Rust, MIT/Apache) first, IgH
  (nixpkgs, igc native driver on 6.12 LTS) as fallback; no PLC.
- EtherCAT I/O: EK1100, EL1809, EL2809, EL3102 (warp lasers sampled with
  the spindle position, ~1,000 points a turn at 1 ms).
- Safety stays hardwired (safety relay, contactor; no STO at 100 W).
- Edge PC with the GPU stays off the real-time loop.
- BOM: drives, encoder, controller and I/O lines with sources; total
  USD 16,112 to 32,938 (THB 0.53M to 1.09M). Next step: EtherCAT bench.
- Investor render: cabinet and outfeed labels.
1.5 MiB
3851x2334px
1.5 MiB
3851x2334px